AT A GLANCE:
General information
This section applies to anyone who lifts loads using the crane, performs work on the crane, or works nearby.
At the start
Using this product manual
The following symbols are used in this product manual:
- This is an instruction regarding an action and prompts you to perform a work step.
- This is the result of an action and describes what happens on the device.
- This is a list.
Only with...
A section that appears in a box framed by a dashed line is only applicable for certain types, versions or options. The condition to which the section applies is specified at the beginning in the heading “Only with...”.
Instructions for the product manual
Read the product manual through carefully before beginning work. Also be sure to observe additional product manuals for accessories and components.
Afterwards, keep the product manual available in the vicinity of the crane. It must be accessible to all who work with or on the crane.
In the case of reselling or hiring out, always provide the product manual together with the crane.
Proper use
The ABUS load indicator system LIS-SE is a load measurement and evaluation system designed for hoists and crane installations. The LIS-SE is intended especially for use in hoist control systems. Its main function is overload protection through evaluation of the current and voltage of the hoist motor. An optional load population recorder can be used to log the actual operating mode of the hoist. The LIS-SE is intended especially for use in pole-switchable three-phase motors.
Regulations
The installation has been built and tested according to European standards, rules and regulations applicable at the time of its manufacture. The conventions applied during design and construction are specified in the Declaration of Conformity or the Declaration of Incorporation. The conventions must also be observed for installation, operation, inspection and maintenance, as must the applicable occupational health and safety regulations.
Which provision applies in individual cases will greatly depend on the crane’s use and the national regulations. Review and observe all applicable and current regulations, including the occupational health and safety regulations. Refer also to the Declaration of Conformity or Declaration of Incorporation.
Warranty
- ABUS assumes no liability for damages that were caused by improper use, inadequately trained personnel, incorrect performance of work, nor for any changes, reconstruction or other modification of the crane or crane components which were not approved by ABUS.
- Safe operation of the crane or crane components is only guaranteed if original ABUS replacement parts are used.
Instructions regarding safety
Observe these instructions for safe handling of the crane. Special hazard notices are located in the corresponding sections in which the danger arises.
- Before commissioning, it must be checked that the wiring of the installation conforms to the wiring diagram.
- Before working on the crane, disconnect the power line and wait at least four minutes until the voltage has dissipated.
- Only have trained electricians perform the work on the crane electrical system!
- Changes that impair safety, as well as extensions and modifications, are prohibited and may only be carried out by ABUS. Opening the LIS-SE is prohibited!
- Wrong parameterisation and settings could lead to a possible overload of the crane, causing a load drop.
- If the LIS-SE is incorrectly connected, the LIS‑SE itself or other components could be damaged.
The LIS-SE
Description of the device
LIS-SE:
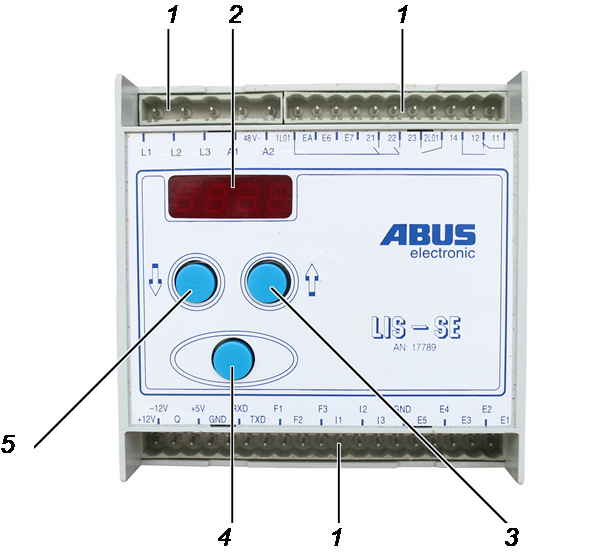
- 1: Pin multipoint connector
- 2: Display
- 3: Arrow button “up”
- 4: Enter
- 5: Arrow button “down”
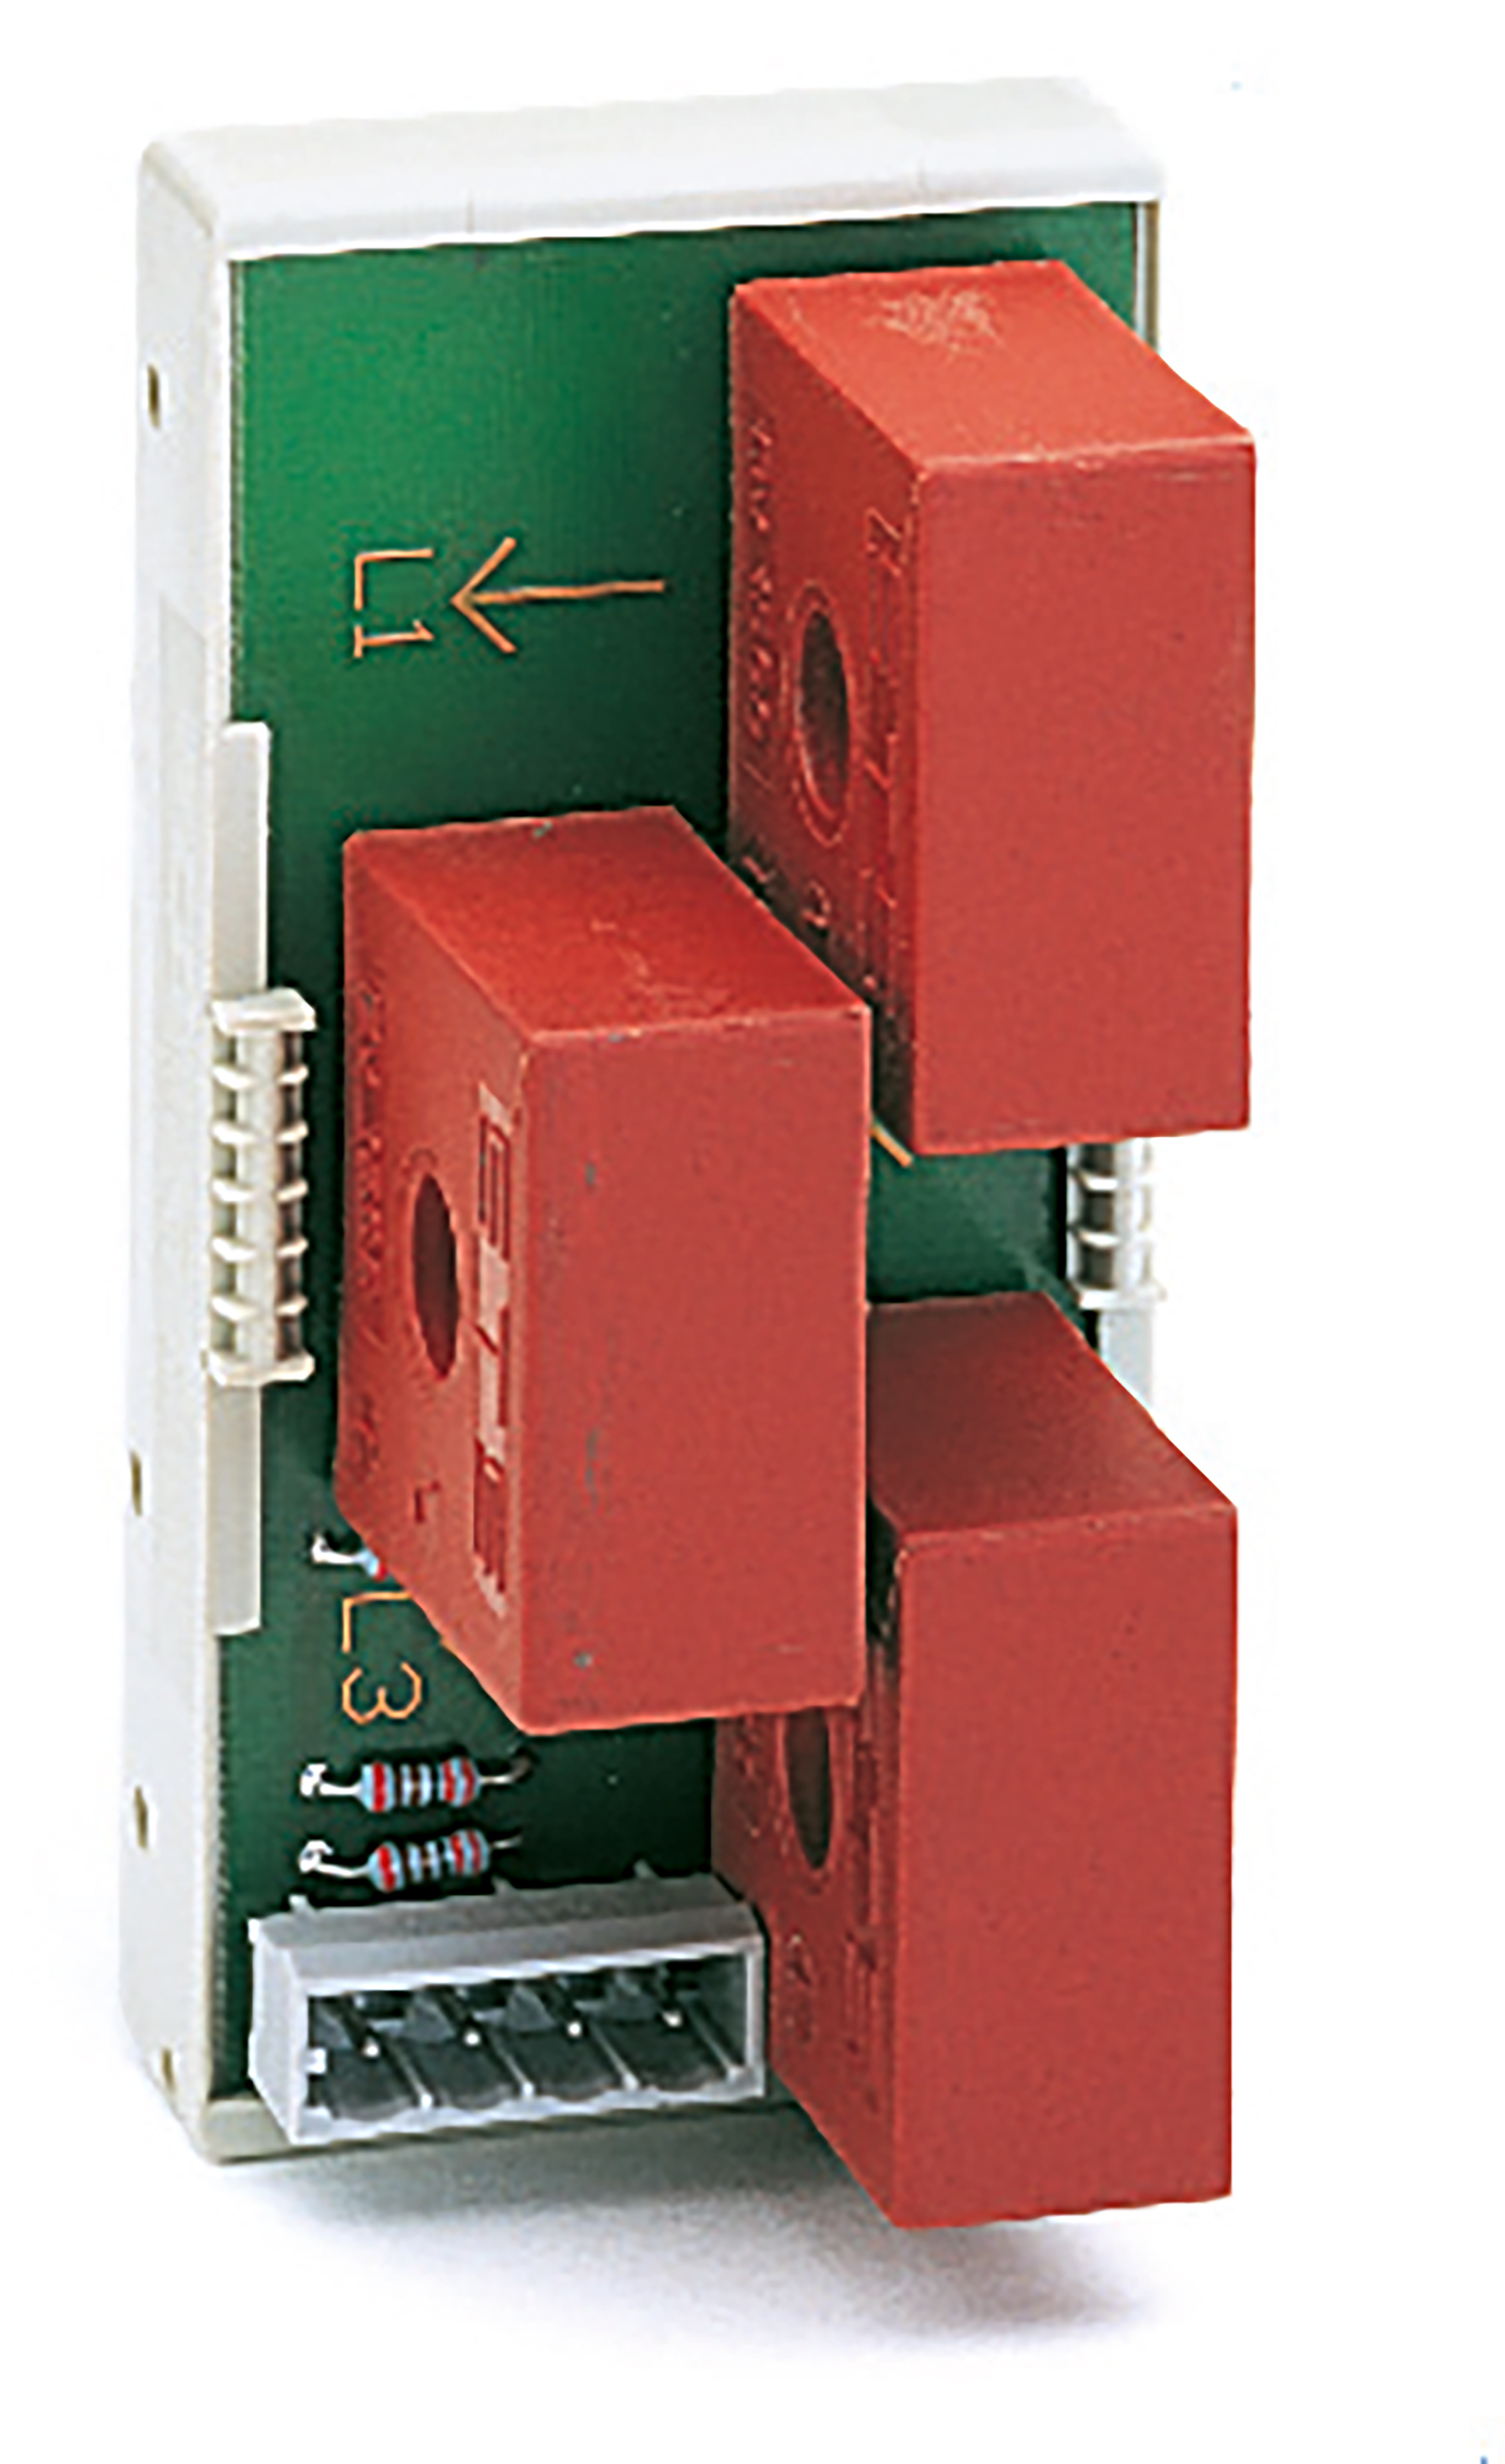
Current transformer module:
Performance features
Load indicator system LIS-SE:
- The LIS-SE is a microcontroller-controlled system for load measurement and evaluation on hoists.
- The main function of the LIS-SE is overload protection of the hoist through evaluation of the current and voltage of the hoist motor. The message of an overload can be sent visually as well as acoustically. The switching points of the overload protection can be set to maximally 110 % of the maximum load capacity. The switching points can be set variably in 2 % steps.
- Lifting the load with a sudden jolt is prevented by the switch-off of the fast lifting speed in the event of a rapid load increase.
- The LIS-SE can additionally output status or error messages.
- The load population recorder (option) shows the theoretical service life of the crane, its actual hours of use, the number of operating hours and the crane's remaining service life.
- The LIS-SE galvanically isolates the signals at the inputs from those at the outputs.
- The automatically controlled regenerative braking during lowering increases the service life of the brakes.
- The permanent monitoring of the motor current with commensurate switching of the contactors extends the service life of the contactors.
- The hoist motor always starts at slow lifting speed and switches to fast lifting speed only after a set time has elapsed, thus preventing a rapid load increase and reducing the start-up current.
- Two or more hoists can be monitored in joint operation. This does NOT correspond to the synchronization control system! The synchronization control system is a separate ABUS product.
- An inching counter prevents the lifting of the load in inching operation. When the set number is exceeded, lifting is no longer possible. Operation can be resumed by pressing the “Lower” button for at least 3 s.
Current transformer module:
- The load evaluation is carried out through the measurement of the voltage and current in the connection cables of the hoist to be monitored.
- An external current transformer module performs the measurement.
- The size of the current transformer modules depends on the rated current of the hoist motor at fast lifting speed.
Technical data
LIS-SE
LIS-SE |
|||
|---|---|---|---|
Operating voltage A1, A2 |
230 V ±10% |
110 V ±10% |
48 V ±10% |
Input voltage |
230 V ±10% |
110 V ±10% |
48 V ±10% |
Measurement range |
0 V – 627 V |
||
Current transformer module, input |
0 V – 7.24 V |
||
Mains frequency |
50 Hz – 60 Hz |
||
Switching contacts |
250 V, 8 A |
||
Power consumption |
Max. 15 VA |
||
Ambient temperature |
-20 °C to +55 °C |
||
Output voltage of load display |
5 V, max. 250 mA |
||
Display signal Q |
Serial data log ±12 V |
||
Maximum acceleration time of the hoist motor |
Slow lifting speed: 150 ms Fast lifting speed: 460 ms |
||
Relative humidity |
5% − 85%, non-condensing |
||
Disposing of the LIS-SE
If the LIS must be disposed of:
- Dismantle the LIS components as far as possible.
- Observe local regulations concerning disposal and recycling.
- Dispose of the individual parts sorted by material in an environmentally sound manner.
- Remove electronic assemblies and dispose of in accordance with local regulations for scrap electronic parts.
- The plastic housing should be recycled with plastic waste.
Operating the LIS-SE
All settings and displays in the main menu (parameter level) of the LIS are shown through parameters. Each parameter is shown on the display as a two-digit or three-digit number. Most parameters have a value that can be displayed or adjusted.
Functions of the buttons
DownUp
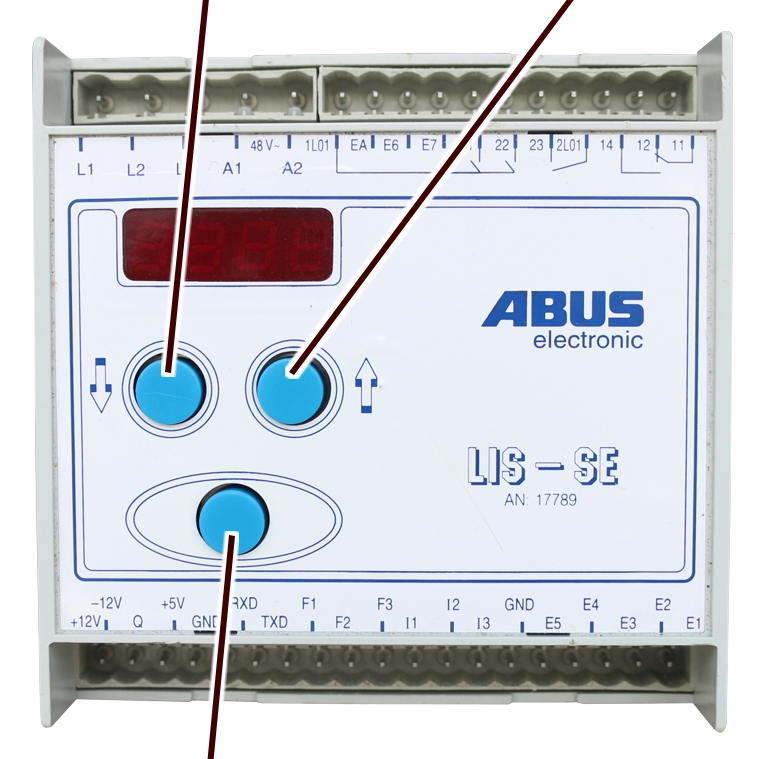
- Enter:
Brief pressing during input of a value or a number: jumps to the next digit.
Brief pressing within a parameter: saves the changed value.
Brief pressing during input of the code: confirms the code.
Holding pressed within a parameter: opens the display for entering the code to change the value.
Holding pressed after entering the PIN: opens the parameter level.
- Up and down arrow buttons:
In the parameter level: selects a parameter.
When entering a value: input of numbers.
Entering numbers
Note
The input of numbers always follows the same principle, regardless of whether the input concerns parameter values, the code or the PIN number. There are always only 4 digits displayed, since the display can only show 4 digits. However, larger numbers can also be entered. In this case, the digits after the decimal are pushed out of the display and are thus no longer visible.
- Input the first digit with the arrow buttons.
- Briefly press Enter to jump to the next digit.
- Repeat the procedure for the input of the next digits.
Setting option:
The table shows an example of the setting options for the parameter P 6.1. For some parameters however, the setting options are also prescribed. With regard to the load capacity, 100 t can also be entered, for example.
Example P 6.1:
Display |
Position |
Setting option |
|---|---|---|
0.000 |
1st digit |
0 ‒ 97 |
0.000 |
2nd digit |
0 ‒ 9 |
0.000 |
3rd digit |
0 ‒ 9 |
0.000 |
4th digit |
0 ‒ 9 |
Setting a two- or three-digit number at the first position:
If the number changes from single-digit to two-digit or three-digit, the decimal in the display is moved by one or two places. The decimal places are then pushed out of the display, since only 4 digits can be displayed.
The input of the numbers always begins on the right with the third decimal place.
Value to be entered |
Input in the LIS |
Display in the LIS |
|---|---|---|
1250 kg |
1.250 |
1.250 |
10,250 kg |
10.250 |
10.25 |
100,000 kg |
100.000 |
100.0 |
Example, single digit:
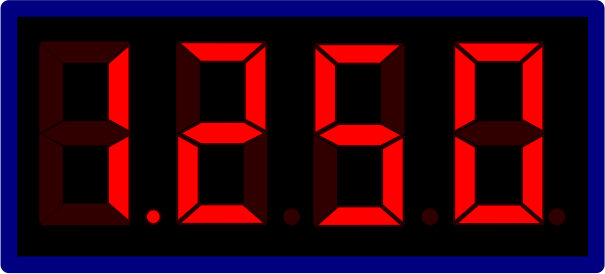
- Enter value of 1250 kg with the arrow buttons and Enter.
Example, two digits:
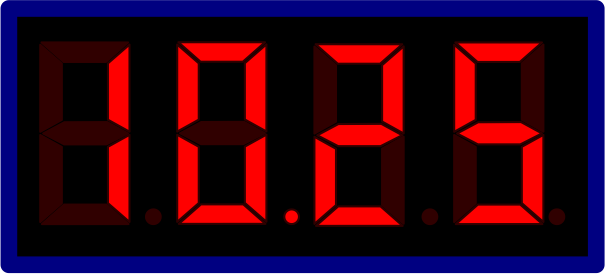
- Enter value of 10,250 kg with the arrow buttons and Enter.
Opening the parameter level
Only with load population recorder
With an LIS with load population recorder, the load population recorder can be read before calling up the parameter level. The reading of the load population recorder can be skipped by briefly pressing Enter.
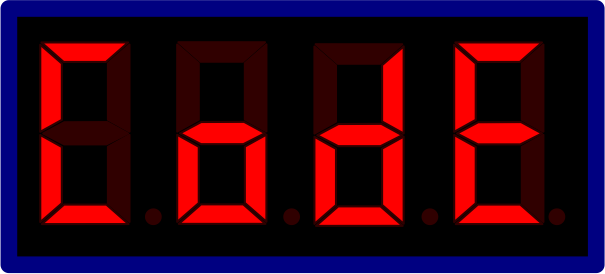
- Hold Enter pressed until “Code” appears in the display.
- While Enter is held pressed, the current operating hours are briefly displayed.
Reading the load population recorder:
- Hold Enter pressed.
- Enter code 2223.
- Press Enter briefly.
- The current values of the load population recorder are displayed. See “P 5.2 Load population recorder”.
Skipping the load population recorder:
- If the load population recorder is not to be read out, this section may be skipped.
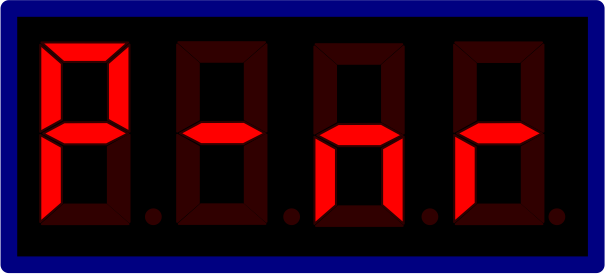
- Press Enter briefly.
- “P - nr.” is shown in the display.
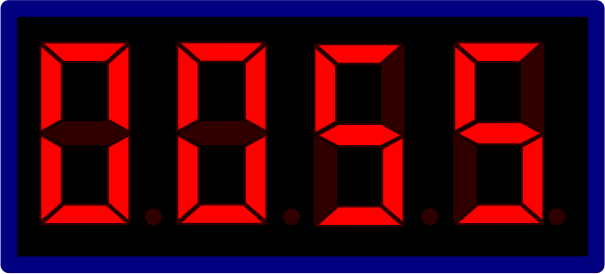
- Hold Enter pressed.
- Enter PIN 0055.
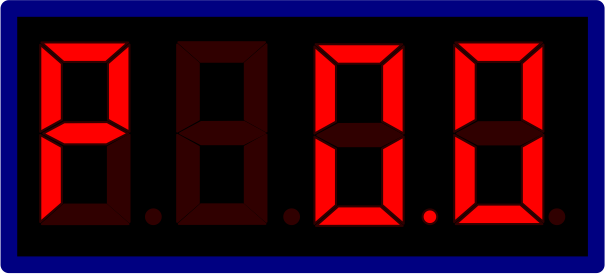
- Hold Enter pressed until P 0.0 appears in the display.
- The parameter level is opened.
In the parameter level, the control signals “Lift” and “Lower” are generally disabled, unless it is specifically noted in the corresponding parameter that Lift/Lower is enabled.
- Select the desired parameters with the arrow buttons and carry out the settings.
If an incorrect code was entered:
The code or the PIN number may be entered incorrectly a maximum of three times in succession. At the fourth incorrect entry, the LIS is locked and [no] appears in the display.
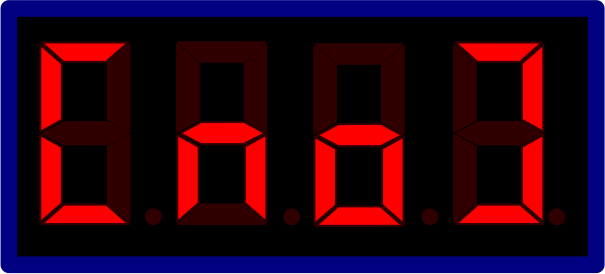
Note
The LIS continues working with the last entered values. To be unlocked, the LIS must be sent in. In this case, contact your ABUS Service representative. See “ABUS Service”.
Changing values
For some parameters, the values can be changed in the parameter level. In this case, the current value is always initially shown, which can then be changed. To prevent unintended changes, the code 1443 must be entered prior to changing the value.
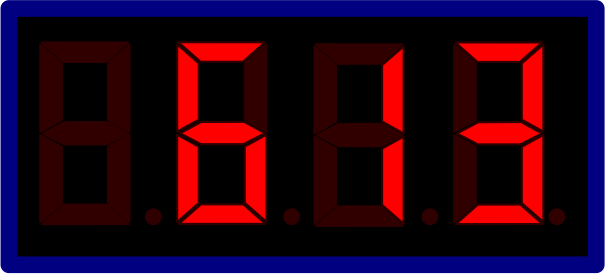
- A parameter is opened.
- The current value is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Enter code 1443.
- Press Enter briefly.
- Enter the value.
- Press Enter briefly.
- “SP” is briefly shown on the display.
- The value is saved.
Closing the parameter level
The parameter level must always be exited with the parameter P 9.9 so that the values are saved and the overload protection is activated again!
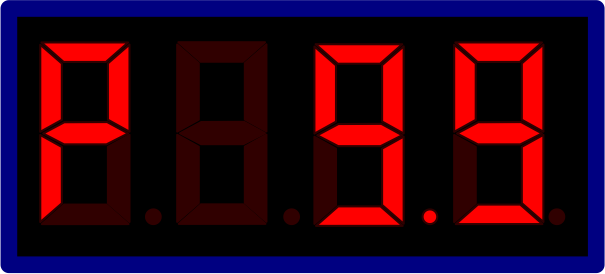
- Select parameter P 9.9 with the arrow buttons.
- Press Enter briefly.
- The parameter level is closed.
Display in operating mode
Standby mode:
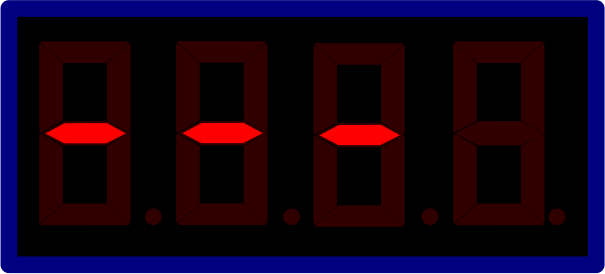
- Continuous bar from left to right through the display.
“Lift” control signal:
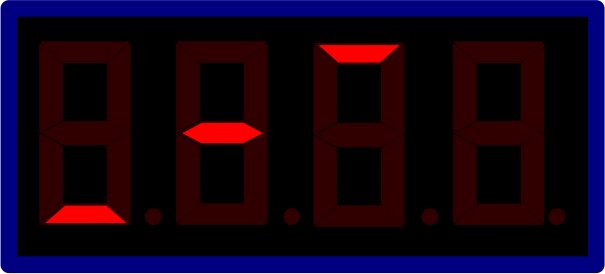
- Bars run from bottom left toward top right through the display (rising staircase curve).
“Lower” control signal:
- Bars run from top left toward bottom right through the display (descending staircase curve).
Overview of parameters
Note
The specified parameters are located on the second parameter level. The parameters P 5.0, P 5.01, and P 5.4 require a special code and can therefore only be set with an authorisation from ABUS.
Access to the third parameter level is reserved for ABUS!
Parameter |
Setting range / unit |
Name |
See |
|---|---|---|---|
P 0.0 |
0 t – 100 t |
Maximum load capacity |
|
P 0.1 |
0 t – 80 t |
Maximum load capacity of hoist 1 |
|
P 1.1 |
0 – 17 |
Motor type |
|
P 1.2 |
0 – 97, 999 |
Winding resistance |
|
P 1.3 |
Current correction factor |
||
P 2.1 |
Setting slow lifting speed |
||
P 2.2 |
Setting fast lifting speed |
||
P 2.3 |
Setting with test load (teach-in) |
||
P 2.4 |
Device diagnosis |
||
P 3.0 |
In t |
Load display |
|
P 3.1 |
In kW |
Rotating field power |
|
P 3.2 |
In t |
Load display with deactivated overload protection |
|
P 3.3 |
In A |
Motor current |
|
P 3.4 |
In V |
Mains voltage |
|
P 3.41 |
Mains voltage analysis |
||
P 4.0 |
0% − 110% |
Load-controlled switching point |
|
P 4.1 |
0% − 110% |
Switching point of overload protection of hoist 1 |
|
P 4.2 |
0% − 110% |
Second load-controlled switching point |
|
P 4.3 |
Without function |
||
P 4.4 |
0, 1, 2 |
Operation on a twin hoist |
|
P 5.0 |
300 ms – 460 ms |
Measuring time extension |
|
P 5.01 |
20 − 255 |
Sensitivity of “rapid load increase” |
|
P 5.1 |
In h |
Theoretical service life |
|
P 5.2 |
In h |
Reading the load population recorder |
|
P 5.3 |
Test at the inspection before initial commissioning |
||
P 5.4 |
12 – 30 |
Inching counter |
|
P 5.5 |
Delete all values |
||
P 6.1 |
In h |
Input of starting value |
|
P 6.2 |
In h |
Actual hours of use S |
|
P 6.3 |
In h |
Operating hours Ti |
|
P 6.4 |
In h |
Input of theoretical service life |
|
P 6.5 |
Deleting load population recorder |
“P 6.5 Deleting values (including load population recorder)” |
|
P 7.0 |
Accessing parameter level 3 |
||
P 9.9 |
Exiting the parameter level |
Installing and connecting
This section applies to anyone who works on the crane prior to its use.
The end user of the crane is responsible for the proper qualifications of the commissioning personnel.
Examples of qualified persons:
- Persons with comprehensive knowledge from specialist training in engineering and in the electrical systems of cranes.
- Persons with sufficient experience in the operation, installation and maintenance of cranes.
- Persons with comprehensive knowledge regarding the relevant technical rules, directives and safety regulations applicable in the respective country.
- Persons receiving regular training from ABUS.
ABUS assumes no liability for damage due to incorrectly performed commissioning work done by unqualified personnel.
ABUS recommends having the commissioning work performed by the ABUS assembly team.
Connecting the crane with LIS‑SE
- Connect according to the wiring diagram.
Checking the factory setting
- Lift the test load.
- Compare the value shown by the LIS-SE under parameter P 3.0 with the test load.
If the deviation is greater than 10 %, the corresponding parameters must be adjusted!
In this case, an adjustment with test load (teach-in) is necessary. See “P 2.3 Setting with test load (teach-in)”.
Reading and setting the LIS-SE
If the LIS-SE is not preset or the settings need to be adapted, the corresponding parameters must be adjusted.
P 0.0 Maximum load capacity
In this parameter you enter the maximum load capacity of the crane.
Since this has no influence on the evaluation of LIS however, no adjustment is necessary here.
- Select parameter P 0.0 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Enter the maximum load capacity of the crane with the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 0.1 Maximum load capacity of hoist 1
In this parameter you enter the maximum load capacity of the hoist.
In the range of up to 10 t, the maximum load capacity can be set in steps of 100 kg. In the range of over 10 t, the maximum load capacity can be set in steps of 500 kg and for over 20 t it can be set in steps of 1 t.
- Select parameter P 0.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Enter the maximum load capacity of the hoist with the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 1.1 Motor type
In this parameter you set the motor type. For ABUS motors, tables in which the respective motor type can be read are provided in the following pages. The corresponding number can be selected in the parameter.
- Select parameter P 1.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Select motor type according to the tables below.
- Select the corresponding number of the motor type with the arrow buttons.
- Press Enter briefly.
- The value is saved.
Note
If a motor type was selected from the table, the parameters P 1.2 and P 1.3 do not need to be set. These are then set automatically.
If the motor type is not shown in the table or corresponds to the number 0:
- Select 0 as the number.
- Set parameters P 1.2 and P 1.3. See “P 1.2 Winding resistance”.
Selection of the motor type for voltage range 3 (star connection):
380 V – 415 V, 50 Hz // 440 V – 480 V, 60 Hz
Hoist motor |
Current transformer module |
|||||||
|---|---|---|---|---|---|---|---|---|
Hoist |
Motor type Input of P1.1 |
P [kW] 50 Hz 12/2-pin |
IN [A] 12/2-pin |
R [in Ohm] Input of P1.2 |
Measurement range |
IN [A] |
Correction factor P 1.3 |
Article number |
Third-party motor |
0 |
See type plate |
Measure |
Select the current transformer module according to the rated current and enter the correction factor of the corresponding current transformer module. |
||||
GM800 L.4 |
1 |
0.28/1.9 |
1.8/5.0 |
28.2/4.06 |
I |
8 |
306 |
9743 |
GM800 H.4 |
2 |
0.45/3.2 |
3.1/7.2 |
21.0/2.16 |
I |
8 |
306 |
9743 |
GM800 U.4 |
0 |
0.55/4.0 |
4.0/8.5 |
17.6/1.76 |
I |
8 |
306 |
9743 |
GM1000 L.6 |
3 |
0.45/3.0 |
2.4/7.7 |
18.6/2.16 |
I |
8 |
306 |
9743 |
GM1000 H.6 |
4 |
0.8/4.9 |
4.4/11.2 |
11.2/1.3 |
II |
16 |
613 |
9744 |
GM1000 U.6 |
0 |
0.9/6.0 |
4.6/13 |
10.2/1.05 |
II |
16 |
613 |
9744 |
GM2000 L.3 |
5 |
0.8/4.9 |
4.4/11.2 |
11.2/1.3 |
II |
16 |
613 |
9744 |
GM2000 H.3 |
6 |
1.1/7.6 |
5.1/15.9 |
8.65/0.79 |
II |
16 |
613 |
9744 |
GM3000 L.4 |
7 |
1.2/7.4 |
5.6/15.3 |
10.4/1.0 |
II |
16 |
613 |
9744 |
GM3000 H.4 |
8 |
1.9/12.3 |
8.2/22.9 |
6.65/0.51 |
III |
23 |
873 |
9745 |
GM5000 L.3 |
9 |
1.9/12.3 |
8.2/22.9 |
6.65/0.51 |
III |
23 |
873 |
9745 |
GM5000 H.3 |
10 |
2.9/18.8 |
12.2/34 |
3.97/0.27 |
IV |
36 |
1381 |
9746 |
GM6000 L |
11 |
2.9/18.8 |
12.2/34 |
3.97/0.27 |
IV |
36 |
1381 |
9746 |
GM7000 L |
13 |
2.4/16 |
11/29.5 |
4.48/0.42 |
IV |
36 |
1381 |
9746 |
GM7000 H |
14 |
4.8/32 |
22/59 |
2.24/0.212 |
V |
60 |
2344 |
9747 |
GM7000 M |
15 |
3/20 |
13.5/39.5 |
3.97/0.27 |
IV |
36 |
1381 |
9746 |
GM7000 U |
16 |
6/40 |
27/79 |
1.99/0.135 |
VI |
136 |
5169 |
19682 |
GM1000 H |
17 |
0.8/4.9 |
4.4/11.2 |
8.5/1.3 |
II |
16 |
613 |
9744 |
Selection of the motor type for voltage range 3 (delta connection):
220 V – 240 V, 50 Hz // 255 V – 280 V, 60 Hz
Hoist motor |
Current transformer module |
|||||||
|---|---|---|---|---|---|---|---|---|
Hoist |
Motor type Input of P1.1 |
P [kW] 50 Hz 12/2-pin |
IN [A] 12/2-pin |
R [in Ohm] Input of P1.2 |
Measurement range |
IN [A] |
Correction factor P 1.3 |
Article number |
Third-party motor |
0 |
See type plate |
Measure |
Select the current transformer module according to the rated current and enter the correction factor of the corresponding current transformer module. |
||||
GM800 L.4 |
0 |
0.28/1.9 |
3.1/8.7 |
4.7/0.677 |
I |
8 |
306 |
9743 |
GM800 H.4 |
0 |
0.45/3.2 |
5.4/12.5 |
7/0.72 |
II |
16 |
613 |
9744 |
GM800 U.4 |
0 |
0.55/4.0 |
6.9/14.7 |
5.86/0.585 |
II |
16 |
613 |
9744 |
GM1000 L.6 |
0 |
0.45/3.0 |
4.2/12.8 |
6.15/0.707 |
II |
16 |
613 |
9744 |
GM1000 H.6 |
0 |
0.8/4.9 |
7.6/19.4 |
3.70/0.43 |
III |
23 |
873 |
9745 |
GM1000 U.6 |
0 |
0.9/6.0 |
8.0/22.5 |
3.4/0.35 |
III |
23 |
873 |
9745 |
GM2000 L.3 |
0 |
0.8/4.9 |
7.6/19.4 |
3.70/0.43 |
III |
23 |
873 |
9745 |
GM2000 H.3 |
0 |
1.1/7.6 |
8.8/27.5 |
2.9/0.26 |
IV |
36 |
1381 |
9746 |
GM3000 L.4 |
0 |
1.2/7.4 |
9.7/26.5 |
3.45/0.33 |
IV |
36 |
1381 |
9746 |
GM3000 H.4 |
0 |
1.9/12.3 |
14.2/39.7 |
22.2/0.17 |
IV |
36 |
1381 |
9746 |
GM5000 L.3 |
0 |
1.9/12.3 |
14.2/39.7 |
2.22/0.17 |
IV |
36 |
1381 |
9746 |
GM5000 H.3 |
0 |
2.9/18.8 |
21.1/59 |
1.31/0.09 |
V |
60 |
2344 |
9747 |
GM6000 L |
0 |
2.9/18.8 |
21.1/59 |
1.31/0.09 |
V |
60 |
2344 |
9747 |
GM7000 L |
0 |
2.4/16 |
19.1/51 |
1.49/0.141 |
V |
60 |
2344 |
9747 |
GM7000 H |
0 |
4.8/32 |
38.2/102 |
0.745/0.07 |
VI |
136 |
5169 |
19682 |
GM7000 M |
0 |
3/20 |
23.4/69 |
1.31/0.09 |
VI |
136 |
5169 |
19682 |
GM7000 U |
0 |
6/40 |
46.8/138 |
0.44/0.045 |
VI |
136 |
5169 |
19682 |
Selection of the motor type for voltage range 5 (star connection):
460 V – 500 V, 50 Hz // 550 V – 600 V, 60 Hz
Hoist motor |
Current transformer module |
|||||||
|---|---|---|---|---|---|---|---|---|
Hoist |
Motor type Input of P1.1 |
P [kW] 50 Hz 12/2-pin |
IN [A] 12/2-pin |
R [in Ohm] Input of P1.2 |
Measurement range |
IN [A] |
Correction factor P 1.3 |
Article number |
Third-party motor |
0 |
See type plate |
Measure |
Select the current transformer module according to the rated current and enter the correction factor of the corresponding current transformer module. |
||||
GM800 L.4 |
0 |
0.28/1.9 |
1.5/4.1 |
20.3/2.9 |
I |
8 |
306 |
9743 |
GM800 H.4 |
0 |
0.45/3.2 |
2.6/6 |
25.4/2.59 |
I |
8 |
306 |
9743 |
GM800 U.4 |
0 |
0.55/4.0 |
3.3/7.1 |
26.1/2.5 |
I |
8 |
306 |
9743 |
GM1000 L.6 |
0 |
0.45/3.0 |
2.6/6.2 |
26.8/3.07 |
I |
8 |
306 |
9743 |
GM1000 H.6 |
0 |
0.8/4.9 |
3.7/9.3 |
15.45/1.94 |
II |
16 |
613 |
9744 |
GM1000 U.6 |
0 |
0.9/6.0 |
3.8/10.8 |
15.5/1.32 |
II |
16 |
613 |
9744 |
GM2000 L.3 |
0 |
0.8/4.9 |
3.7/9.3 |
15.45/1.97 |
II |
16 |
613 |
9744 |
GM2000 H.3 |
0 |
1.1/7.6 |
4.3/13.3 |
12.5/1.14 |
II |
16 |
613 |
9744 |
GM3000 L.4 |
0 |
1.2/7.4 |
4.7/12.7 |
15.8/1.46 |
II |
16 |
613 |
9744 |
GM3000 H.4 |
0 |
1.9/12.3 |
6.8/19.1 |
9.15/0.67 |
III |
23 |
873 |
9745 |
GM5000 L.3 |
0 |
1.9/12.3 |
6.8/19.1 |
9.15/0.67 |
III |
23 |
873 |
9745 |
GM5000 H.3 |
0 |
2.9/18.8 |
10.2/28.3 |
5.6/0.414 |
IV |
36 |
1381 |
9746 |
GM6000 L 3 |
0 |
2.9/18.8 |
10.2/28.3 |
5.6/0.414 |
IV |
36 |
1381 |
9746 |
GM7000 L |
0 |
2.4/16 |
9.2/24.6 |
6.15/0.64 |
IV |
36 |
1381 |
9746 |
GM7000 H |
0 |
4.8/32 |
18.4/49.2 |
3.075/0.32 |
V |
60 |
2344 |
9747 |
GM7000 M |
0 |
3/20 |
11.3/33 |
5.6/0.414 |
IV |
36 |
1381 |
9746 |
GM7000 U |
0 |
6/40 |
22/66 |
2.8/0.207 |
V |
60 |
2344 |
9747 |
Selection of the motor type for voltage range 1 (star connection):
300 V – 335 V, 50 Hz // 360 V – 400 V, 60 Hz
Hoist motor |
Current transformer module |
|||||||
|---|---|---|---|---|---|---|---|---|
Hoist |
Motor type Input of P1.1 |
P [kW] 50 Hz 12/2-pin |
I [A] 12/2-pin |
R [in Ohm] Input of P1.2 |
Measurement range |
IN [A] |
Correction factor P 1.3 |
Article number |
Third-party motor |
0 |
See type plate |
Measure |
Select the current transformer module according to the rated current and enter the correction factor of the corresponding current transformer module. |
||||
GM800 L.4 |
0 |
0.34/2.3 |
2.3/8.3 |
8.9/1.28 |
I |
8 |
306 |
9743 |
GM800 H.4 |
0 |
0.54/3.8 |
3.9/9.1 |
13.3/1.35 |
II |
16 |
613 |
9744 |
GM800 U.4 |
0 |
0.66/4.8 |
5.0/10.7 |
11.1/1.08 |
II |
16 |
613 |
9744 |
GM1000 L.6 |
0 |
0.54/3.6 |
3/9.3 |
11.7/1.34 |
II |
16 |
613 |
9744 |
GM1000 H.6 |
0 |
0.96/5.9 |
5.5/14 |
7.08/0.82 |
II |
16 |
613 |
9744 |
GM1000 U.6 |
0 |
1.1/7.2 |
5.8/16.4 |
6.37/0.59 |
II |
16 |
613 |
9744 |
GM2000 L.3 |
0 |
0.96/5.9 |
5.5/14 |
7.08/0.82 |
II |
16 |
613 |
9744 |
GM2000 H.3 |
0 |
1.3/9.1 |
6.4/20 |
5.47/0.5 |
III |
23 |
873 |
9745 |
GM3000 L.4 |
0 |
1.44/8.9 |
6.7/18.3 |
6.65/0.59 |
III |
23 |
873 |
9745 |
GM3000 H.4 |
0 |
2.3/14.8 |
9.8/27.5 |
4.09/0.34 |
IV |
36 |
1381 |
9746 |
GM5000 L.3 |
0 |
2.3/14.8 |
9.8/27.5 |
4.09/0.34 |
IV |
36 |
1381 |
9746 |
GM5000 H.3 |
0 |
3.5/22.6 |
15.3/43 |
2.6/0.15 |
V |
60 |
2344 |
9747 |
GM6000 L 3 |
0 |
3.5/22.6 |
15.3/43 |
2.6/0.15 |
V |
60 |
2344 |
9747 |
GM7000 L |
0 |
2.9/19.2 |
11.6/31 |
2.79/0.268 |
IV |
36 |
1381 |
9746 |
GM7000 H |
0 |
5.8/38.4 |
23.2/62 |
1.4/0.134 |
V |
60 |
2344 |
9747 |
GM7000 M |
0 |
3.6/24 |
14.2/42 |
2.6/0.15 |
V |
60 |
2344 |
9747 |
GM7000 U |
0 |
7.2/48 |
28.4/84 |
1.3/0.075 |
VI |
136 |
5169 |
19682 |
Selection of the motor type for voltage range 1 (delta connection):
175 V – 195 V, 50 Hz // 208 V – 230 V, 60 Hz
Hoist motor |
Current transformer module |
|||||||
|---|---|---|---|---|---|---|---|---|
Hoist |
Motor type Input of P1.1 |
P [kW] 50 Hz 12/2-pin |
IN [A] 12/2-pin |
R [in Ohm] Input of P1.2 |
Measurement range |
IN [A] |
Correction factor P 1.3 |
Article number |
Third-party motor |
0 |
See type plate |
Measure |
Select the current transformer module according to the rated current and enter the correction factor of the corresponding current transformer module. |
||||
GM800 L.4 |
0 |
0.34/2.3 |
4/10.9 |
2.95/0.42 |
II |
16 |
613 |
9744 |
GM800 H.4 |
0 |
0.54/3.8 |
6.7/15.7 |
4.4/0.45 |
II |
16 |
613 |
9744 |
GM800 U.4 |
0 |
0.66/4.8 |
8.7/18.5 |
3.7/0.36 |
III |
23 |
873 |
9745 |
GM1000 L.6 |
0 |
0.54/3.6 |
5.2/16 |
3.88/0.44 |
II |
16 |
613 |
9744 |
GM1000 H.6 |
0 |
0.96/5.9 |
9.5/24.2 |
2.33/0.27 |
III |
23 |
873 |
9745 |
GM1000 U.6 |
0 |
1.1/7.2 |
10.0/28.3 |
2.13/0.20 |
IV |
36 |
1381 |
9746 |
GM2000 L.3 |
0 |
0.96/5.9 |
9.5/24.2 |
2.33/0.27 |
III |
23 |
873 |
9745 |
GM2000 H.3 |
0 |
1.3/9.1 |
11.1/35 |
1.80/0.166 |
IV |
36 |
1381 |
9746 |
GM3000 L.4 |
0 |
1.44/8.9 |
11.6/31.7 |
2.22/0.196 |
IV |
36 |
1381 |
9746 |
GM3000 H.4 |
0 |
2.3/14.8 |
17/47.6 |
1.366/0.114 |
V |
60 |
2344 |
9747 |
GM5000 L.3 |
0 |
2.3/14.8 |
17/47.6 |
1.366/0.114 |
V |
60 |
2344 |
9747 |
GM5000 H.3 |
0 |
3.5/22.6 |
26.5/74 |
0.866/0.05 |
VI |
136 |
5169 |
|
GM6000 L 3 |
0 |
3.5/22.6 |
26.5/74 |
0.866/0.05 |
VI |
136 |
5169 |
|
GM7000 L |
0 |
2.9/19.2 |
20.1/54 |
0.93/0.09 |
V |
60 |
2344 |
9747 |
GM7000 H |
0 |
5.8/38.4 |
40.2/108 |
0.465/0.045 |
VI |
136 |
5169 |
19682 |
GM7000 M |
0 |
3.6/24 |
25/73 |
0.866/0.05 |
VI |
136 |
5169 |
19682 |
GM7000 U |
0 |
7.2/48 |
50/146 |
0.433/0.025 |
VI |
136 |
5169 |
19682 |
P 1.2 Winding resistance
With this parameter you enter the ohmic resistance of the winding for the fast and slow lifting speeds. The winding resistance [in ohms] is measured directly on the motor or on the central control at contactor K23.
Opening/reading parameters
- Select parameter P 1.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The value of the winding resistance at slow lifting speed is displayed.
- Press Enter briefly.
- The value of the winding resistance at fast lifting speed is displayed.
- Press Enter briefly.
- “└ - -” is shown in the display.
- Press Enter briefly.
- Parameter P 1.2 is displayed.
Setting parameters:
- Select parameter P 1.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value of the winding resistance at slow lifting speed is displayed.
- Press Enter briefly.
- The current value of the winding resistance at fast lifting speed is displayed.
- Press Enter briefly.
- “└ - -” is shown in the display.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- Enter the first value of the resistance [in ohms] for the slow lifting speed using the arrow buttons.
- Press Enter briefly.
- Enter the second value of the resistance [in ohms] for the fast lifting speed using the arrow buttons.
- Press Enter briefly.
- The values are saved.
P 1.3 Current correction factor
In this parameter you enter the correction factor of the current transformer modules from ABUS. Take the values from the following table.
Measurement range |
IN [A] current transformer module |
Correction factor |
Article number |
|---|---|---|---|
0 |
3 |
0115 |
19683 |
I |
8 |
0306 |
9743 |
II |
16 |
0613 |
9744 |
III |
23 |
0873 |
9745 |
IV |
36 |
1381 |
9746 |
V |
60 |
2344 |
9747 |
VI |
136 |
5169 |
19682 |
- Select parameter P 1.3 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value is displayed.
- Hold Enter pressed.
- Enter value from the table with the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 2.1 Setting slow lifting speed
With this parameter you can read the saved values for the slow lifting speed or enter new values.
Display |
Number |
Meaning |
|---|---|---|
Last |
-1- |
Test load with empty load hook at slow lifting speed. |
Po-r |
-1- |
Rotating field power with empty load hook at slow lifting speed. |
Last |
-2- |
Test load at slow lifting speed. |
Po-r |
-2- |
Rotating field power with test load at slow lifting speed. |
Reading out values:
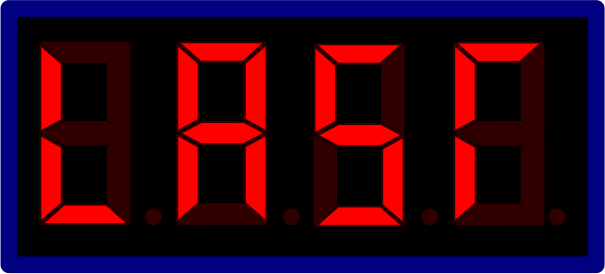
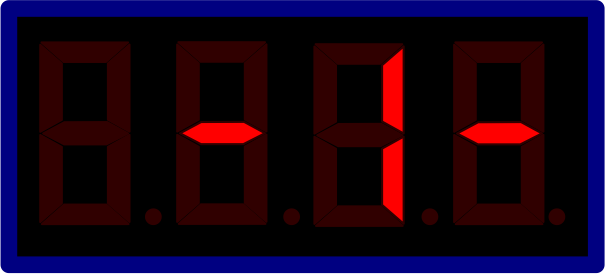
- Select parameter P 2.1 with the arrow buttons.
- Press Enter briefly.
- “Last” and then “-1-” is shown on the display.
- Press Enter briefly.
- The saved value for “Last -1-” is displayed.
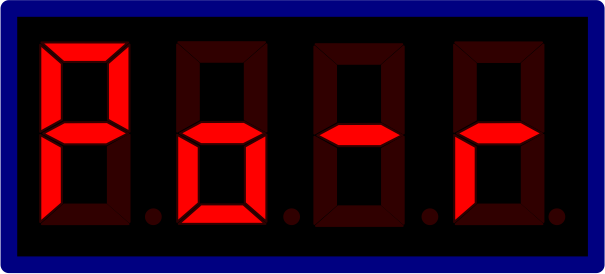
- Press Enter briefly.
- “Po-r” and then “-1-” is shown on the display.
- Press Enter briefly.
- The saved value for “Po-r -1-” is displayed.
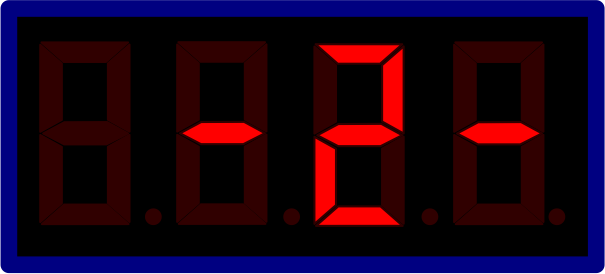
- Press Enter briefly.
- “Last” and then “-2-” is shown on the display.
- Press Enter briefly.
- The saved value for “Last -2-” is displayed.
- Press Enter briefly.
- “Po-r” and then “-2-” is shown on the display.
- Press Enter briefly.
- The saved value for “Po-r -2-” is displayed.
Entering values:
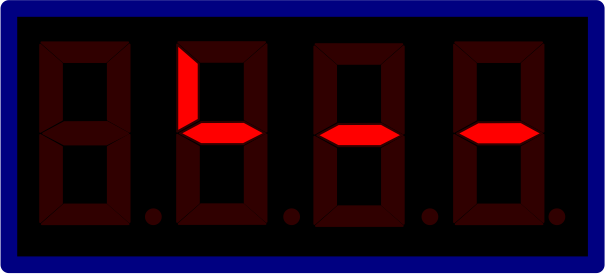
- Select parameter P 2.1 with the arrow buttons.
- Press Enter repeatedly until “└ - -” is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- “Last” and then “-1-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Last -1-” with the arrow buttons.
- Press Enter briefly.
- “Po-r” and then “-1-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Po-r -1-” with the arrow buttons.
- Press Enter briefly.
- “Last” and then “-2-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Last -2-” with the arrow buttons.
- Press Enter briefly.
- “Po-r” and then “-2-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Po-r -2-” with the arrow buttons.
- Press Enter briefly.
- P 2.1 is displayed and the values are saved.
P 2.2 Setting fast lifting speed
Under this parameter you can read the saved values for the fast lifting speed or enter new values.
Display |
Number |
Meaning |
|---|---|---|
Last |
-1- |
Test load with empty load hook at fast lifting speed. |
Po-r |
-1- |
Rotating field power with empty load hook at fast lifting speed. |
Last |
-2- |
Test load at fast lifting speed. |
Po-r |
-2- |
Rotating field power with test load at fast lifting speed. |
Reading out values:
- Select parameter P 2.2 with the arrow buttons.
- Press Enter briefly.
- “Last” and then “-1-” is shown on the display.
- Press Enter briefly.
- The saved value for “Last -1-” is displayed.
- Press Enter briefly.
- “Po-r” and then “-1-” is shown on the display.
- Press Enter briefly.
- The saved value for “Po-r -1-” is displayed.
- Press Enter briefly.
- “Last” and then “-2-” is shown on the display.
- Press Enter briefly.
- The saved value for “Last -2-” is displayed.
- Press Enter briefly.
- “Po-r” and then “-2-” is shown on the display.
- Press Enter briefly.
- The saved value for “Po-r -2-” is displayed.
Entering values:
- Select parameter P 2.2 with the arrow buttons.
- Press Enter repeatedly until “└ - -” is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- “Last” and then “-1-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Last -1-” with the arrow buttons.
- Press Enter briefly.
- “Po-r” and then “-1-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Po-r -1-” with the arrow buttons.
- Press Enter briefly.
- “Last” and then “-2-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Last -2-” with the arrow buttons.
- Press Enter briefly.
- “Po-r” and then “-2-” is shown on the display.
- Press Enter briefly.
- Input the desired value for “Po-r -2-” with the arrow buttons.
- Press Enter briefly.
- P 2.2 is displayed and the values are saved.
P 2.3 Setting with test load (teach-in)
With this parameter the rotating field power is recorded according to a defined procedure for both the slow and fast lifting speeds. The procedure occurs in two steps. In the first step, the rotating field power is measured with empty load hook and in the second step with a test load. The LIS-SE uses these values to calculate a proportional function (load line), which in turn is used in later operation to calculate the respective current load from the rotating field power.
All subsequent steps must be completely carried out, since otherwise the setting is not completed and error messages can arise!
Note
To set the test load, a test load with known weight is required. The test load should be 80 % of the maximum load capacity.
The test load must be at least 40 % of the maximum load capacity. If a setting is made with a test load between 40 % and 80 % of the maximum load capacity, this must be noted in the test log book.
The closer the test load is to the maximum load capacity, the more accurate will be the displayed weight of the load.
Tip:
Several measurements are carried out in the following. After each measurement, the load hook can be lowered so that there is enough lifting height available for the next measurement.
Entering the value of the test load:
- Select parameter P 2.3 with the arrow buttons.
- Press Enter briefly
- The parameter is opened.
- Load is displayed.
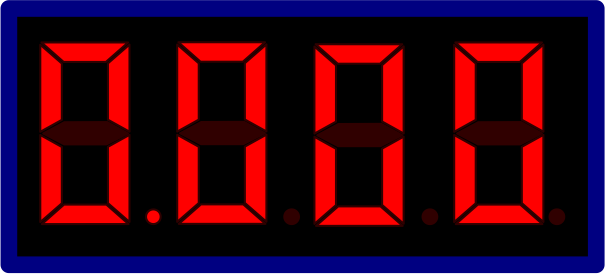
- Hold Enter pressed until “0.000” is displayed.
- Enter value of the test load with the arrow buttons.
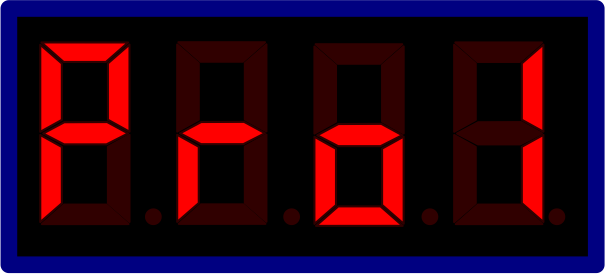
- Press Enter briefly.
- The LIS-SE displays “Pro1”.
Measuring rotating field power without test load:
- With slow lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at slow lifting speed has been performed.
- The LIS-SE saved the value.
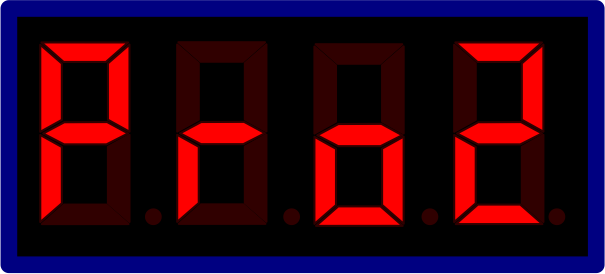
- The display shows “Pro2”.
- With fast lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at fast lifting speed has been performed.
- The LIS-SE saved the value.
Measuring rotating field power with test load:
- Lower load hook.
- Attach test load.
- Lift test load until it is hanging freely.
- Hold emergency stop pressed for at least 5 s.
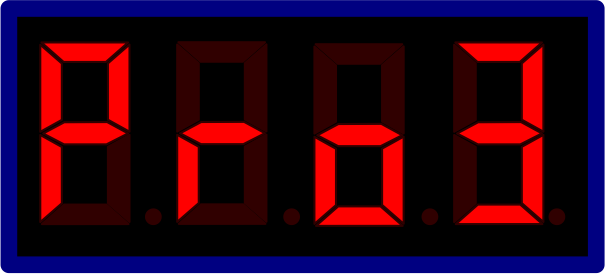
- The LIS-SE displays “Pro3”.
- With slow lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at slow lifting speed with test load has been performed.
- The LIS-SE saved the value.
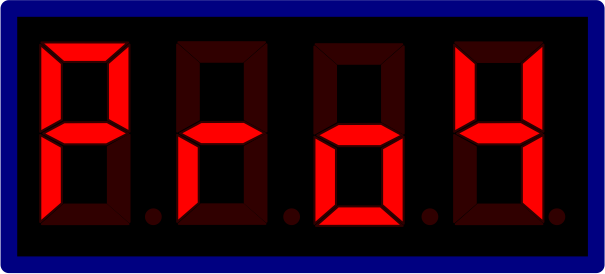
- The LIS-SE displays “Pro4”.
- With fast lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at fast lifting speed with test load has been performed.
- The LIS-SE saved the value.
Note
The LIS-SE switches to the mode for measuring with test load and 0.000 is shown in the display.
Checking the value:
- Lift up the test load and hold “Lift” pressed in fast lifting speed until the hoist motor shuts off automatically.
- Set down the test load.
- Compare the value of the test load with the display on the LIS-SE.
The value is allowed to deviate up to ±10 %. Otherwise the measurement must be repeated.
- Call up the parameter level.
- Exit the parameter level with parameter P 9.9 to confirm the settings.
- Press “Lower” for approx. 2 s to conclude the setting.
- Teach-in is completed and the LIS-SE is ready for operation.
P 2.4 Device diagnosis
This parameter is used to manually switch the relays of the LIS-SE. The control signal can also be checked at the inputs E1 to E7 and EA.
Note
The parameter is divided into 3 areas:
- Test of the relays for the outputs
- Test of the second load-controlled switching point
- Test of the inputs E1 – E7, EAThe hoist does not lift and lower if this parameter is active!
- Select parameter P 2.4 with the arrow buttons.
- Press Enter briefly.
- “Code” is displayed.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- The parameter is opened.
- Call up the next switching points in the table one after another by pressing Enter.
The different switching points in the table allow the relays for the outputs and inputs to be checked. Checking the second load-controlled switching point is not yet possible.
Test of the relays for the outputs |
|||||||
|---|---|---|---|---|---|---|---|
Status of the switching contacts |
Display |
Remark |
Error case display |
||||
Test point |
Lift |
Lower |
Fast |
Monitoring |
|||
- - 0 - |
0 |
0 |
0 |
0 |
0001 |
All relays in standby |
0000 |
- - 1 - |
1 |
0 |
0 |
0 |
1000 |
Relay for “Lift” switched |
1001 |
- - 2 - |
0 |
1 |
0 |
0 |
0100 |
Relay for “Lower” switched |
0101 |
- - 3 - |
0 |
0 |
1 |
1 |
0011 |
Relay for “Fast” switched |
0010 |
Test of the second load-controlled switching point |
|
|---|---|
- - 4 - |
Test for the second load-controlled switching point: not currently active! |
- - 5 - |
|
Test of the inputs E6/E2/E7/EA |
|||||||
|---|---|---|---|---|---|---|---|
Status of the inputs |
Display |
Remark |
Error case display |
||||
Test point |
E6 |
E2 |
E7 |
EA |
|||
- - 6 - |
0 |
0 |
0 |
0 |
4000 |
No signal at the inputs Monitoring OK |
0000 |
1 |
0 |
0 |
0 |
0001 |
Signal at input for “Lift” |
4000 |
|
0 |
1 |
0 |
0 |
0020 |
Signal at input for “Lower” |
4000 |
|
1 |
0 |
1 |
1 |
0301 |
Signal at input for “Fast/Lift” |
4000 |
|
0 |
1 |
1 |
1 |
0320 |
Signal at input for “Fast/Lower” |
4000 |
|
Test of the inputs E5/E4/E3/E1 |
|||||||
|---|---|---|---|---|---|---|---|
Status of the inputs |
Display |
Remark |
Error case display |
||||
Test point |
E5 |
E4 |
E3 |
E1 |
|||
- - 7 - |
Input E1 not active! |
||||||
Input E3 not active! |
|||||||
0 |
1 |
0 |
0 |
0700 |
Signal at input E4 evaluated (optional – only with two trolleys in joint operation) |
0000 |
|
1 |
0 |
0 |
0 |
8000 |
Signal at input E5 evaluated (optional – only with two trolleys in joint operation) |
0000 |
|
P 3.0 Load display
This parameter shows the value [in t] of the last lifted load. This is only possible with the motor running. After switching off the motor or when lowering, the last displayed value is shown again. When lifting is resumed, the load display is updated and shows the current value of the load. The crane is therefore functional in this parameter and can lift/lower.
The overload protection is active in this parameter.
- Select parameter P 3.0 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and “ABUS“ and “00.00” are shown alternatingly in the display.
- Lift the load.
- The current value of the raised load and “ABUS” are shown alternatingly in the display.
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
P 3.1 Rotating field power
In this parameter you can read the currently evaluated rotating field power [in kW]. The measurement can only be made with the motor running in “Lift” mode. After switching off the motor, the last displayed value is shown until a new measurement is made. The crane is therefore functional in this parameter and can lift/lower.
The overload protection is deactivated in this parameter.
- Select parameter P 3.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the current value is displayed.
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
P 3.2 Load display with deactivated overload protection
As in parameter P 3.0, but the overload protection is deactivated! The crane is nevertheless functional in this parameter and can lift/lower, since the raised load can only be measured with the motor running.
- Select parameter P 3.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and “ABUS“ and “00.00” are shown alternatingly in the display.
- Lift the load.
- The current value of the raised load and “ABUS” are shown alternatingly in the display.
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
P 3.3 Motor current
With this parameter you can read the motor current [in A]. The measurement can only be made with the motor running. After switching off the motor, the display remains unchanged until a new measurement is made. The crane is therefore functional in this parameter and can lift/lower.
- Select parameter P 3.3 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and 00.00 is shown in the display.
- Press “Lift” or “Lower”.
- The current value is displayed.
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
P 3.4 Mains voltage
With this parameter you can read the mains voltage [in V]. After switching off the motor, the display remains unchanged until a new measurement is made. The crane is functional in this parameter and can lift/lower.
- Select parameter P 3.4 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the current value is displayed.
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
P 3.41 Mains voltage analysis
This parameter is used for simple and fast diagnosis and measurement of the mains voltage curve at the start of fast lifting speed. The measurement is performed with the motor running, and the crane is therefore functional in this parameter and can lift/lower.
The crane should be positioned as far as possible from the feed unit of the conductor system so that the voltage drop on the conductor system is also measured.
A total of 10 values of the mains voltage are measured [in V]. At the start of the fast lifting speed, the mains voltage is measured every 50 ms.
- Position the crane as far as possible from the feed unit of the conductor system.
- Attach test load.
- Lift test load 2 s with slow lifting speed and then switch to fast lifting speed for at least 2 s.
- Select parameter P 3.41 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The first value is displayed.
- To go to the next value, press Enter briefly.
Value |
|
|---|---|
1 |
Mains voltage which was measured at slow lifting speed 50 ms before switching to fast lifting speed. |
2 |
Mains voltage which was measured at the time point of switching from the slow to the fast lifting speed. |
3 to 10 |
Mains voltage which was measured thereafter in intervals of 50 ms. |
For a mains voltage of altogether 400 V, the allowed deviation of the measured values from the data sheet is maximally -6.5%. These values must not fall below this limit!
Next, the parameter level must be called up again in order to exit the parameter:
- Hold Enter pressed until “Code” or “P-nr” appears in the display.
- Open the parameter level.
- Exit the parameter level via P 9.9.
- Set down the test load.
P 4.0 Load-controlled switching point
In this parameter you set the load-controlled switching point in the range from 0 % to 110 % of the maximum load capacity. The value can be set in 2% steps.
The load-controlled switching point is activated through the switching of input EA on the LIS-SE. This enables, for example, implementation of partial load ranges (reduced maximum load capacity of the main girder, e.g. on the edge), which are switched by a cross-type limit switch.
- Select parameter P 4.0 with the arrow buttons.
- Press Enter briefly.
- Set the value between 0 % and 110 % of the maximum load capacity.
- Press Enter briefly.
- The value is saved.
P 4.1 Switching point of overload protection of hoist 1
In this parameter you set the switching point of the overload protection in the range from 0 % to 110 % of the maximum load capacity. The value can be set in 2 % steps.
This switching point is activated when the input EA on the LIS-SE is not switched.
- Select parameter P 4.1 with the arrow buttons.
- Press Enter briefly.
- Set the value between 0 % and 110 % of the maximum load capacity.
- Press Enter briefly.
- The value is saved.
P 4.2 Second load-controlled switching point
In this parameter you can set a second load-controlled switching point in the range from 0 % to 110 % of the maximum load capacity. The value can be set in 2 % steps.
The second load-controlled switching point switches a relay on the current transformer module, through which, for example, a horn can issue a warning signal when the maximum load capacity of 100 % is exceeded.
- Select parameter P 4.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Set the value between 0 % and 110 % of the maximum load capacity.
- Press Enter briefly.
- The value is saved.
P 4.3 Without function
This parameter currently has no function and can therefore be skipped.
P 4.4 Operation on twin hoists
With this parameter you set the time-delayed switching on of the hoists in order to prevent a simultaneous high start-up current in the hoist motors. The parameter can be set with the values 0, 1 and 2.
Value |
Meaning |
|---|---|
0 |
Fast lifting speed without additional time delay |
1 |
0.5 s time delay |
2 |
1 s time delay |
- Select parameter P 4.4 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Depending on area of use, select the following setting with the arrow buttons:
Mode of operation |
Device 1 |
Device 2 |
|---|---|---|
1 hoist |
0 |
- - - |
2 hoists working in parallel |
1 |
1 |
Operation on a twin hoist |
1 |
2 |
- Press Enter briefly.
- The entered value is saved.
P 5.0 Measuring time extension
This parameter enables you to extend the measuring time during start-up of the motor. This can be necessary, for example, due to a mains voltage that is too low, since the start-up current flows for longer than 300 ms. In this case, an overload would be interpreted after 300 ms due to the high start-up current, which is however not an overload but triggered by the lack of motor torque resulting from the insufficient mains voltage.
Note
Default setting: 300 ms
The measuring time can be extended to maximally 460 ms.
The parameter can only be accessed with a special code! Whenever adjustment of the measuring time extension is necessary, contact your ABUS Service representative. See “ABUS Service”.
- Select parameter P 5.0 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code.
- Press Enter briefly.
- Input the value with the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 5.01 Sensitivity of “rapid load increase”
In this parameter you set the sensitivity of the hoist response to lifting with a sudden jolt. When lifting with a sudden jolt occurs, the hoist switches from fast lifting back to slow lifting speed until the rapid load increase is over.
The value has no unit of measurement and can be set between 20 and 255. In this range, 20 is very sensitive and 255 is the lowest sensitivity.
Note
The parameter can only be accessed with a special code! Whenever adjustment of the rapid load increase is necessary, contact your ABUS Service representative. See “ABUS Service”.
- Select parameter P 5.01 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code.
- Press Enter briefly.
- Input the value with the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 5.1 Theoretical service life
This parameter shows the full-load hours of the relevant classification according to FEM in which the hoist is classified.
If the load population recorder is not active, 0000 is displayed.
Classification according to FEM |
Full-load hours |
|
|---|---|---|
1Dm |
M1 |
100 |
1Cm |
M2 |
200 |
1Bm |
M3 |
400 |
1Am |
M4 |
800 |
2m |
M5 |
1600 |
3m |
M6 |
3200 |
4m |
M7 |
6300 |
5m |
M8 |
12500 |
- Select parameter P 5.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the current value is displayed.
- Press Enter briefly.
- P 5.1 appears on the display.
P 5.2 Load population recorder
This parameter enables you to read out the data of the load population recorder.
This parameter can be called up through the parameter level, or directly from the display in operating mode. See “Opening the parameter level”.
The load population recorder contains a total of 6 values.
Value |
Meaning |
|---|---|
1 |
Theoretical service life D |
2 |
Actual hours of use S |
3 |
Factor of the load spectrum Kmi |
4 |
Operating hours Ti |
5 |
Remaining service life |
6 |
Starting value |
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 2223.
- Press Enter briefly.
- The load population recorder shows the first value.
- Briefly press Enter each time to go to the next digit.
- Hold Enter pressed to exit the load population recorder.
- The LIS is in operating mode.
P 5.3 Test at the inspection before initial commissioning
This parameter is used to manually switch the relays for the outputs of the LIS-SE.
Note
This function is normally used by the expert for the test before initial commissioning.
The overload protection is deactivated in this parameter! After 45 minutes the parameter closes automatically and the overload protection is reactivated.
Display |
Function |
|---|---|
1 |
Lifting/Lowering disabled |
2 |
Slow lifting/lowering enabled |
3 |
Slow and fast lifting/lowering enabled |
4 |
Slow and fast lifting/lowering enabled Second load-controlled switching point bypassed |
5 |
Not assigned |
- Call up parameter P 5.3 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the first value from the table is displayed.
- Press Enter briefly to switch between the values.
- Check functions.
- Hold Enter pressed.
- P 5.3 appears on the display.
P 5.4 Inching counter
Note
The parameter can only be accessed with a special code! Whenever adjustment of the inching counter is necessary, contact your ABUS Service representative. See “ABUS Service”.
Default setting: 16
- Select parameter P 5.4 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current number is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code.
- Press Enter briefly.
- Select number with the arrow buttons.
- Press Enter briefly.
- The number is saved.
P 5.5 Deleting values
This parameter enables you to delete all values except those of the load population recorder.
- Call up parameter P 5.5 with the arrow buttons.
- Press Enter briefly.
- “Code” is displayed.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- “LOE” appears flashing in the display.
- Press Enter and hold it pressed.
- All values except the load population recorder are deleted!
P 6.1 Starting value
In this parameter you can enter a starting value [in h] which is used to calculate the remaining service life by subtraction from the theoretical full-load hours. The starting value specifies the already used full-load hours of the hoist.
This parameter is used if, for example, a new LIS-SE is inserted on an existing hoist.
Level |
|
|---|---|
1 |
Display of saved starting value |
2 |
Input of new starting value |
- Select parameter P 6.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and “STA” is briefly displayed.
- The current starting value is displayed.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- Input the starting value with the arrow buttons.
- Press Enter briefly.
- The starting value is saved.
P 6.2 Actual hours of use S
This parameter shows the value of the actual hours of use [in h].
- Select parameter P 6.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the current value is displayed.
- Press Enter briefly.
- P 6.2 appears on the display.
P 6.3 Operating hours Ti
This parameter shows the operating hours [in h].
- Select parameter P 6.3 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened and the current value is displayed.
- Press Enter briefly.
- P 6.3 appears on the display.
P 6.4 Input of theoretical service life
This parameter is used to define the theoretical service life based on the classification according to FEM and to activate the load population recorder.
If the load population recorder is not active, 0000 is displayed.
Note
The load population recorder can only be activated by ABUS. If the load population recorder is required, contact your ABUS Service representative. See “ABUS Service”.
Classification according to FEM |
Full-load hours |
|
|---|---|---|
1Dm |
M1 |
100 |
1Cm |
M2 |
200 |
1Bm |
M3 |
400 |
1Am |
M4 |
800 |
2m |
M5 |
1600 |
3m |
M6 |
3200 |
4m |
M7 |
6300 |
5m |
M8 |
12500 |
- Select parameter P 6.4 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Enter the theoretical service life as per the classification according to FEM using the arrow buttons.
- Press Enter briefly.
- The value is saved.
P 6.5 Deleting values (including load population recorder)
This parameter enables you to delete all values, including the load population recorder. This is only possible with a special code!
Note
The load population recorder can only be deleted with a special code. If deletion is required, contact your ABUS Service representative. See “ABUS Service”.
- Call up parameter P 6.5 with the arrow buttons.
- Press Enter briefly.
- “Code” is displayed.
- Hold Enter pressed.
- Enter code.
- Press Enter briefly.
- All values including the load population recorder are deleted!
P 7.0 Password input for parameter level 3
Access reserved exclusively for ABUS!
P 9.9 Exiting the parameter level
The parameter level must always be exited with the parameter P 9.9 so that the values are saved and the overload protection is activated again!
- Select parameter P 9.9 with the arrow buttons.
- Press Enter briefly.
- The parameter level is closed.
Maintenance
This section applies to anyone who maintains, repairs or modifies the crane.
The end user of the crane is responsible for the selection and proper qualifications of the maintenance personnel.
Examples of qualified persons:
- Persons with comprehensive knowledge from specialist training in engineering and in the electrical systems of cranes.
- Persons with sufficient experience in the operation, installation and maintenance of cranes.
- Persons with comprehensive knowledge regarding the relevant technical rules, directives and safety regulations applicable in the respective country.
- Persons receiving regular training from ABUS.
ABUS assumes no liability for damage due to incorrectly performed maintenance work done by unqualified personnel.
ABUS recommends having the maintenance work performed by ABUS Service.
Instructions regarding safety when performing maintenance work
Observe the following safety instructions for any maintenance work on the crane with LIS:
- Switch off the mains switch. Secure the switch to ensure it cannot be turned back on accidentally.
- Unplug the mains disconnector plug from the socket on the crane panel. Secure the socket with a padlock to ensure it is not plugged back in accidentally.
- Use suitable lifting platforms and fall protection equipment.
- Adequately cordon off the operating range around the lifting platform.
- Switch off any other cranes using the same crane track or cranes working above or below the crane undergoing maintenance. Secure the switches to ensure they cannot be turned back on accidentally. Otherwise, other cranes could overturn the hoisting platform or crash into the crane undergoing maintenance.
- Notify personnel in the area that maintenance work will be performed.
- Only have trained electricians perform the work on the crane electrical system!
- Even after the emergency stop button has been pressed, life-threatening high voltages are still present in the panels.
Correcting errors on the LIS-SE
If the LIS-SE is not working or functions other than as expected, a malfunction on the LIS-SE may be the cause.
Error messages
In the event of malfunctions on the LIS-SE:
Malfunctions on the LIS-SE are indicated by error messages on the display.
Error messages |
Fault |
Remedy |
|---|---|---|
Err 1 |
Current correction factor was not entered. |
Enter current correction factor under parameter P 1.3. |
Err 2 |
Maximum load capacity was not entered. |
Enter the maximum load capacity under parameter P 0.1. |
Err 3 |
LIS-SE is not set. |
Enter the setting with test load (P 2.3). |
Err 6 |
Displayed in parameter P 2.3 in the case of insufficient test load or if there are errors in the settings or connections. |
Increase test load to at least 40 % of the maximum load capacity and perform the setting with test load again (P 2.3). |
Err 7 |
Settings were not entered correctly; for example, the Lift button being released in teach-in mode in P 2.3 before the measurement had been completed. |
Repeat the settings. |
Err 8 |
Error during saving of the data |
Replace the LIS-SE. |
Err 9 |
Error during reading of the data. |
Hold Enter pressed until the error message disappears. Otherwise, replace the LIS-SE. |
[ no ] |
The PIN or code was entered 4 times incorrectly. |
Request a returns form through ABUS Service and send it in to unlock the device. |
− − 17 |
Inching counter has triggered. |
Hold the lowering button pressed for at least 3 s. |
U_I |
The calculated rotating field power is less than 10 W. |
Faulty contactors |
Wiring error. |
||
Check settings |
||
Insufficient voltage at input 1 L01 |
||
00.00 |
Overload switch-off or inching counter if, without acknowledging the message by lowering, the voltage was switched off and then back on again. |
Hold the lowering button pressed for at least 3 s. |
Overload - flashes once per second |
Overload lifted |
Set down load and reduce the load. |
Overload switch-off has triggered although no overload was lifted. |
Worn contactors |
|
Voltage drop |
||
Power line dimensions too small. |
||
Start-up current too high. |
||
Brake does not release |
||
Wrong motor type set |
Error messages |
Fault |
Remedy |
|---|---|---|
- - H2 |
Switch-off of a hoist in joint operation, e.g. when reaching a limit switch, caused by lifting tackle of unequal length, asymmetrical slinging points or overload of one of the hoists. |
If this is not the case: check signals at input E5. |
Test not OK |
Malfunction of the LIS-SE |
Request a returns form through ABUS Service and send it in. |
Switch-off during fast lifting speed with “Overload” in display (flashes once per second). |
Voltage drop. |
Read out P 3.41. Check power line and boost if necessary. Check main contactors. |
Value over 110 % of load capacity (flashes once per second) |
Overload |
Set down the load. |
Value flashes twice per second |
Motor current display Switch-off of main contactors for 60 s. |
Motor mechanically hampered, e.g. by the brake not opening, a blocked gear unit or defective ball bearing. Contactor faulty, loose connection, faulty current collector. |
Display is dark |
Display operating voltage has dropped out. |
LIS-SE power pack is faulty. |
Replacing the LIS-SE
If the LIS is faulty, it must be replaced.
Note
When replacing the LIS, note and compare the operating voltage of the crane and LIS.
The LIS can be damaged by an incorrect operating voltage.
Reading out values
If the LIS is in standby mode:
- Press Enter briefly.
- The operating hours are displayed.
In operating mode “Lift” or “Lower”:
- Press “Lift” or “Lower”.
- The current value of the operating hours counter is shown on the display for 3 s.
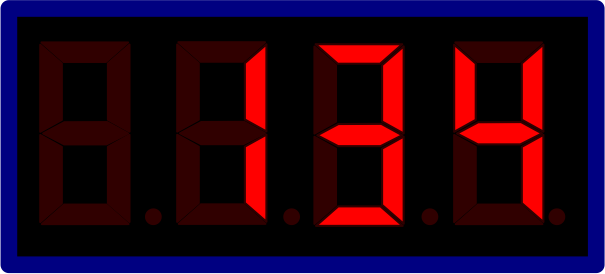
- Note down the operating hours.
- Only with load population recorder:
Note down the value from the load population recorder. See “P 5.2 Load population recorder”. - Note down the values from the parameters P 2.1 and P 2.2.
Disassembling the LIS-SE
Bush multipoint connectorBush multipoint connector
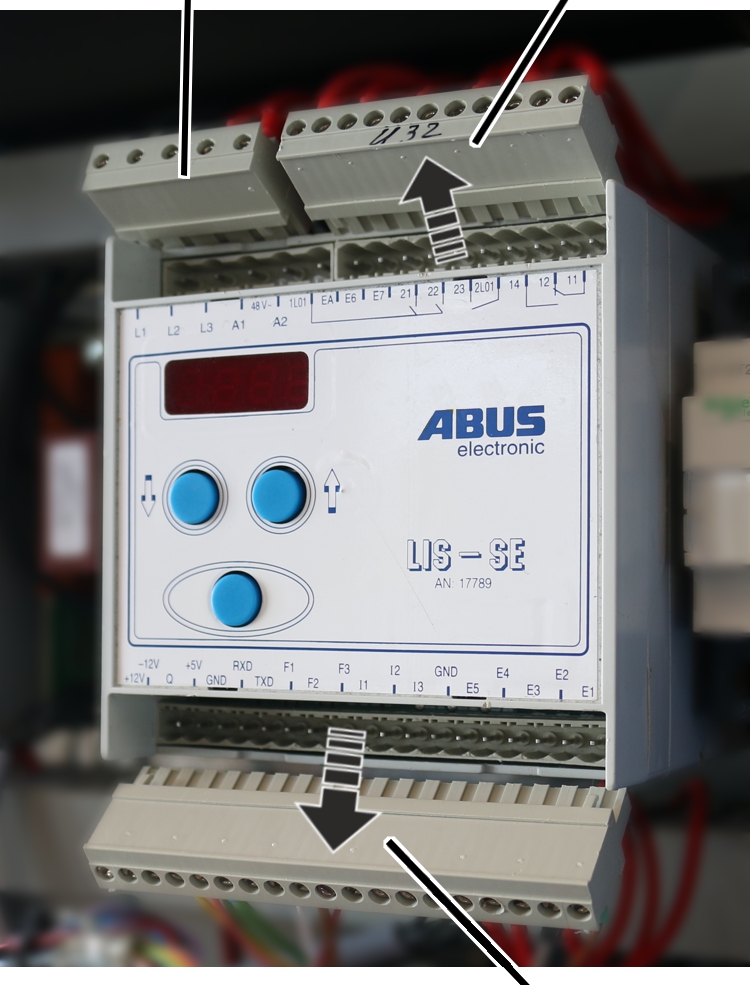
- De-energise the crane.
- Detach the bush multipoint connector from the pin multipoint connector of the LIS-SE.
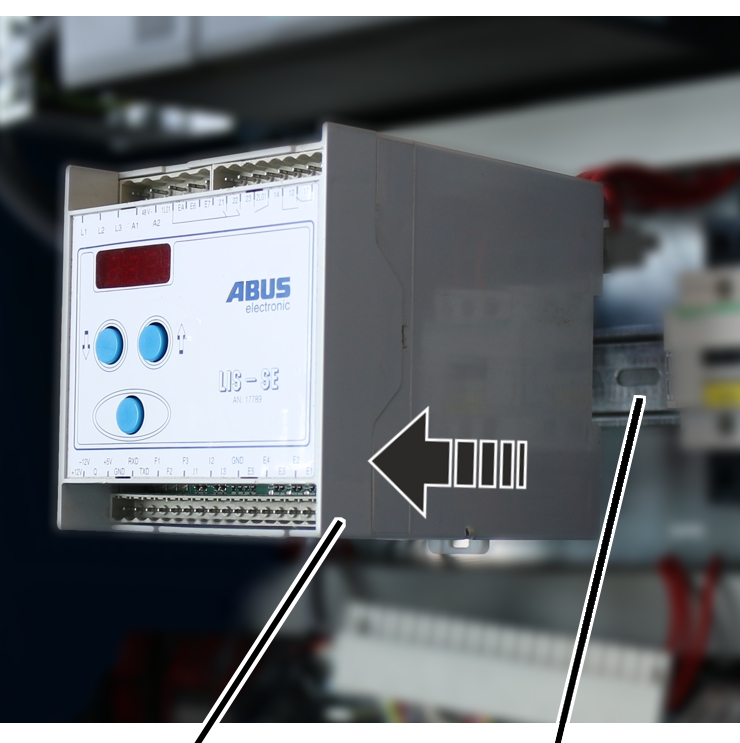
- Pull the LIS-SE from the top-hat rail.
- Take the LIS-SE out of the hoist panel.
Assembling the LIS-SE
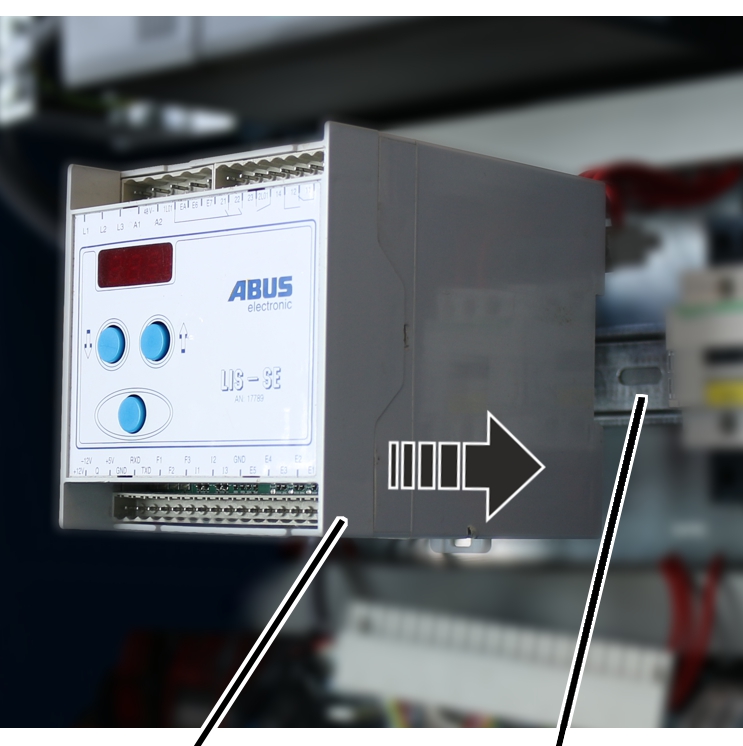
- Insert the new LIS-SE in the hoist panel.
- Push the LIS-SE onto the top-hat rail until it clicks in place.
Bush multipoint connectorBush multipoint connector
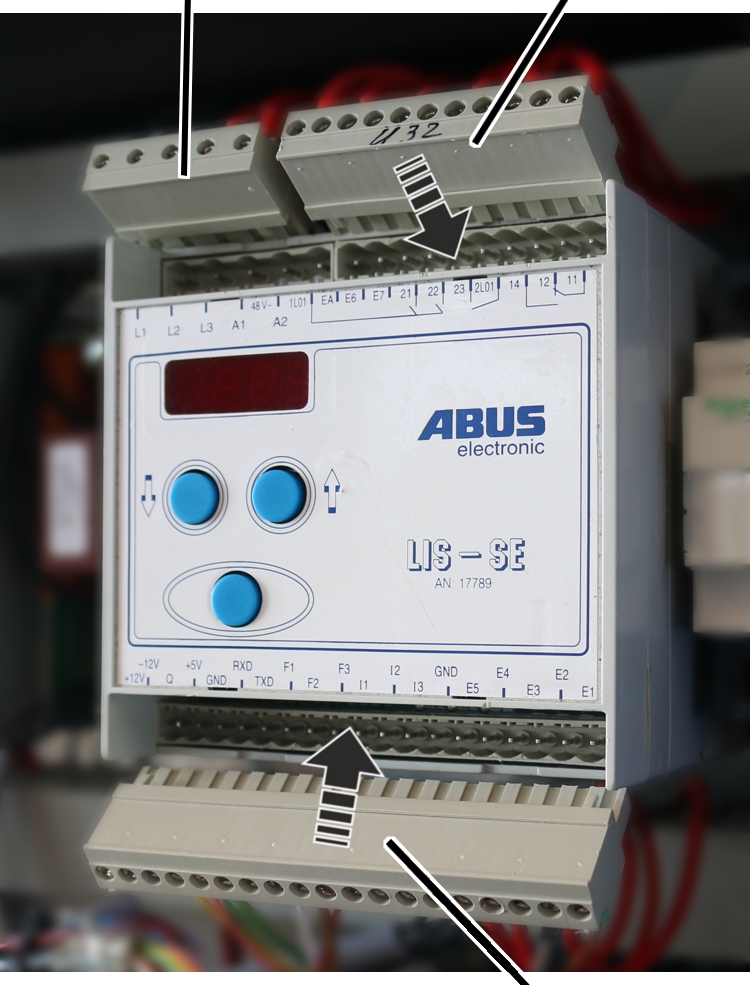
- Insert the bush multipoint connector on the pin multipoint connector of the LIS-SE.
Transferring values
- Switch the crane on.
- Only with load population recorder:
Enter starting value under parameter P 6.1. - Transfer values from the parameters P 2.1 and P 2.2 into the new LIS‑SE.
If the values cannot be adopted, a zero point adjustment must be performed. See “Entering default settings”.
- Write the operating hours and value of the load population recorder on the housing of the new LIS-SE.
Entering default settings
Opening the parameter level
Only with load population recorder
With an LIS with load population recorder, the load population recorder can be read before calling up the parameter level. The reading of the load population recorder can be skipped by briefly pressing Enter.
- Press Enter briefly.
- “P - nr.” is shown in the display.
- Hold Enter pressed.
- Enter PIN 0055.
- Hold Enter pressed until P 0.0 appears in the display.
- The parameter level is opened.
In the parameter level, the control signals “Lift” and “Lower” are generally disabled, unless it is specifically noted in the corresponding parameter that Lift/Lower is enabled.
- Select the desired parameters with the arrow buttons and carry out the settings.
Entering the maximum load capacity of the hoist (P 0.1)
In the range of up to 10 t, the maximum load capacity can be set in steps of 100 kg. In the range of over 10 t, the maximum load capacity can be set in steps of 500 kg and for over 20 t it can be set in steps of 1 t.
- Select parameter P 0.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Enter the maximum load capacity of the hoist with the arrow buttons.
- Press Enter briefly.
- The value is saved.
Selecting motor type (P 1.1)
For ABUS motors, a table is provided in which the respective motor type can be read. See “P 1.1 Motor type”. The corresponding number can be selected in the parameter.
- Select parameter P 1.1 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- Select the motor type according to the table (see “P 1.1 Motor type”).
- Select the corresponding number of the motor type with the arrow buttons.
- Press Enter briefly.
- The value is saved.
Note
If a motor type was selected from the table, the parameters P 1.2 and P 1.3 do not need to be set. These are then set automatically.
If the motor type is not shown in the table or corresponds to the number 0:
- Select 0 as the number.
- Set parameters P 1.2 and P 1.3.
Only with motor type 0
If the motor type is not shown in the table (see “P 1.1 Motor type”) or corresponds to the number 0, the parameters P 1.2 and P 1.3 must be set.
Entering the winding resistance (P 1.2)
With this parameter you enter the ohmic resistance of the winding for the fast and slow lifting speeds. The winding resistance [in ohms] is measured directly on the motor or on the central control at contactor K23.
Setting parameters:
- Select parameter P 1.2 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value of the winding resistance at slow lifting speed is displayed.
- Press Enter briefly.
- The current value of the winding resistance at fast lifting speed is displayed.
- Press Enter briefly.
- “└ - -” is shown in the display.
- Hold Enter pressed until “Code” appears in the display.
- Hold Enter pressed.
- Enter code 1443.
- Press Enter briefly.
- Enter the first value of the resistance [in ohms] for the slow lifting speed using the arrow buttons.
- Press Enter briefly.
- Enter the second value of the resistance [in ohms] for the fast lifting speed using the arrow buttons.
- Press Enter briefly.
- The values are saved.
Entering the current correction factor (P 1.3)
In this parameter you enter the correction factor of the current transformer modules from ABUS. Take the values from the following table.
Measurement range |
IN [A] current transformer module |
Correction factor |
Article number |
|---|---|---|---|
0 |
3 |
0115 |
19683 |
I |
8 |
0306 |
9743 |
II |
16 |
0613 |
9744 |
III |
23 |
0873 |
9745 |
IV |
36 |
1381 |
9746 |
V |
60 |
2344 |
9747 |
VI |
136 |
5169 |
19682 |
- Select parameter P 1.3 with the arrow buttons.
- Press Enter briefly.
- The parameter is opened.
- The current value is displayed.
- Hold Enter pressed.
- Enter value from the table with the arrow buttons.
- Press Enter briefly.
- The value is saved.
Only with load-controlled switching point
If a load-controlled switching point is required, this can be set in parameter P 4.0. Otherwise this setting can be skipped.
Setting the load-controlled switching point (P 4.0)
In this parameter you set the load-controlled switching point in the range from 0 % to 110 % of the maximum load capacity. The value can be set in 2 % steps.
The load-controlled switching point is activated through the switching of input EA on the LIS-SE. This enables, for example, implementation of partial load ranges (reduced maximum load capacity of the main girder, e.g. on the edge), which are switched by a cross-type limit switch.
- Select parameter P 4.0 with the arrow buttons.
- Press Enter briefly.
- Set the value between 0 % and 110 % of the maximum load capacity.
- Press Enter briefly.
- The value is saved.
Setting the switching point of the overload protection for hoist 1 (P 4.1)
In this parameter you set the switching point of the overload protection in the range from 0 % to 110 % of the maximum load capacity. The value can be set in 2 % steps.
This switching point is activated when the input EA on the LIS-SE is not switched.
- Select parameter P 4.1 with the arrow buttons.
- Press Enter briefly.
- Set the value between 0 % and 110 % of the maximum load capacity.
- Press Enter briefly.
- The value is saved.
Entering the setting with test load: Teach-in (P 2.3).
With this parameter the rotating field power is recorded according to a defined procedure for both the slow and fast lifting speeds. The procedure occurs in two steps. In the first step, the rotating field power is measured with empty load hook and in the second step with a test load. The LIS-SE uses these values to calculate a proportional function (load line), which in turn is used in later operation to calculate the respective current load from the rotating field power.
All subsequent steps must be completely carried out, since otherwise the setting is not completed and error messages can arise!
Note
To set the test load, a test load with known weight is required. The test load should be 80 % of the maximum load capacity.
The test load must be at least 40 % of the maximum load capacity. If a setting is made with a test load between 40 % and 80 % of the maximum load capacity, this must be noted in the test log book.
The closer the test load is to the maximum load capacity, the more accurate will be the displayed weight of the load.
Tip:
Several measurements are carried out in the following. After each measurement, the load hook can be lowered so that there is enough lifting height available for the next measurement.
Entering the value of the test load:
- Select parameter P 2.3 with the arrow buttons.
- Press Enter briefly
- The parameter is opened.
- Load is displayed.
- Hold Enter pressed until “0.000” is displayed.
- Enter value of the test load with the arrow buttons.
- Press Enter briefly.
- The LIS-SE displays “Pro1”.
Measuring rotating field power without test load:
- With slow lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at slow lifting speed has been performed.
- The LIS-SE saved the value.
- The display shows “Pro2”.
- With fast lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at fast lifting speed has been performed.
- The LIS-SE saved the value.
Measuring rotating field power with test load:
- Lower load hook.
- Attach test load.
- Lift test load until it is hanging freely.
- Hold emergency stop pressed for at least 5 s.
- The LIS-SE displays “Pro3”.
- With slow lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at slow lifting speed with test load has been performed.
- The LIS-SE saved the value.
- The LIS-SE displays “Pro4”.
- With fast lifting speed, hold “Lift” pressed until the hoist motor shuts off automatically.
- The measurement of the rotating field power at fast lifting speed with test load has been performed.
- The LIS-SE saved the value.
Note
The LIS-SE switches to the mode for measuring with test load and 0.000 is shown in the display.
Checking the value:
- Lift up the test load and hold “Lift” pressed in fast lifting speed until the hoist motor shuts off automatically.
- Set down the test load.
- Compare the value of the test load with the display on the LIS-SE.
The value is allowed to deviate up to ±10 %. Otherwise the measurement must be repeated.
- Call up the parameter level.
- Exit the parameter level with parameter P 9.9 to confirm the settings.
- Press “Lower” for approx. 2 s to conclude the setting.
- Teach-in is completed and the LIS-SE is ready for operation.
Exiting the parameter level (P 9.9)
The parameter level must always be exited with the parameter P 9.9 so that the values are saved and the overload protection is activated again!
- Select parameter P 9.9 with the arrow buttons.
- Press Enter briefly.
- The parameter level is closed.
ABUS Service
Only in Germany
- If available, have the product number, serial number and customer number handy.
- Call the ABUS Service Centre:
- Phone: +49-2261-37-237
- If calling outside the usual business hours, leave a message on the answering machine.
- ABUS Service will return your call promptly.
- If necessary, send a description of the problem by fax or e-mail:
- Fax: +49-2261-37-265
- E-mail: service@abus-kransysteme.de
Only outside Germany
- Call the local ABUS branch or crane service partner.
Your local ABUS branch or crane service partner will provide details of contact data, contacts and availability.
Declaration of Conformity
This declaration is valid as a Declaration of Conformity in terms of the machinery directive of Appendix II 1A.
ABUS Kransysteme GmbH Sonnenweg 1 51647 Gummersbach, Germany |
|
|---|---|
| Product | ABUS Load indicator system LIS-SE in series design |
| Year of construction | From 2000 |
| Order number and serial number | See title page |
| Person responsible for putting together the special technical documentation | Michael Müller Technical Documentation Department manager ABUS Kransysteme GmbH Sonnenweg 1 51647 Gummersbach, Germany |
|
|---|---|---|
| We hereby declare that the product specified above complies with all requirements in the EU directives listed here in the version applicable at the time of issuance. | 2006/42/EG | Machinery |
| 2014/35/EU | Low voltage | |
| 2014/30/EU | Electromagnetic compatibility | |
| In particular, the harmonised standards and national standards, directives and specifications and any other applicable standards have been applied. | EN 13849 | Safety of machinery – Safety-related parts of control systems |
| EN ISO 12100 | Safety of machinery – General principles – Risk assessment and risk reduction | |
| EN 60204 T32 | Electrical equipment of machines, requirements for hoisting machines | |
| EN 61000-6-4 | Electromagnetic compatibility, emitted interference | |
| EN 61000-6-2 | Electromagnetic compatibility, interference immunity | |
Technical documentation is available in full.
The corresponding operating manuals are available in the national language of the user.
With our department for “Technical Documentation”, we have committed ourselves to submitting the specific documentation for the incomplete machine in response to a reasoned request by the market surveillance authorities.
Gummersbach, 20th July 2023
Development of electrical technology
Willi Dick
___________________________
Signature of the authorised person
The content of this declaration complies with EN ISO 17050.
ABUS Kransysteme GmbH supports a quality management system in accordance with DIN EN ISO 9001.